Shallow-π: Knowledge Distillation for Flow-based VLAs
IROS 2026 Best Paper Award Finalist10 of 1,585 accepted (top 0.6%) · 4,348 submitted
AI/ML Research Engineer · Ludo Robotics
I'm a research engineer working on learning-based robot manipulation and humanoids. At Ludo Robotics, I'm building a foundation model for social humanoid interaction.
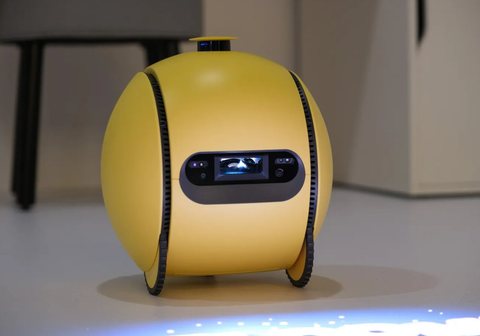
Before that, I spent four years at Samsung Research, working on vision-language-action (VLA) models, imitation-learning policies, and RL fine-tuning for precise manipulation and humanoid control. I also built the sound source localization system for Samsung Ballie.
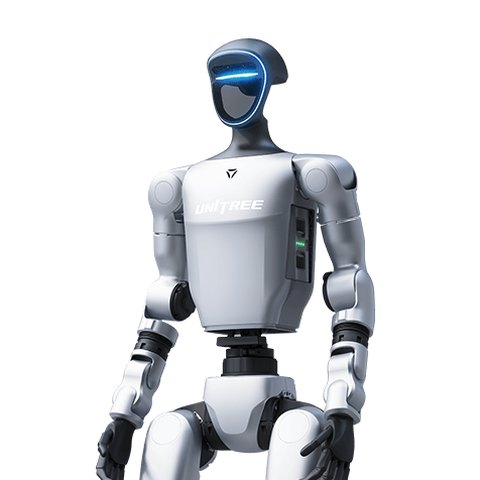
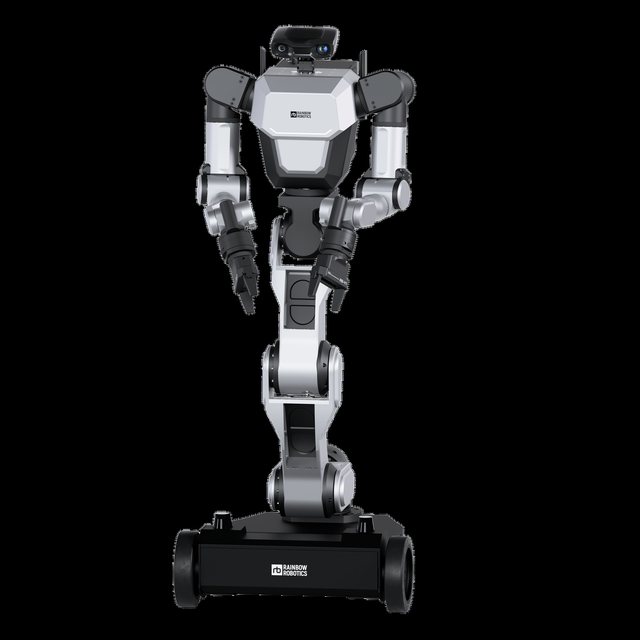
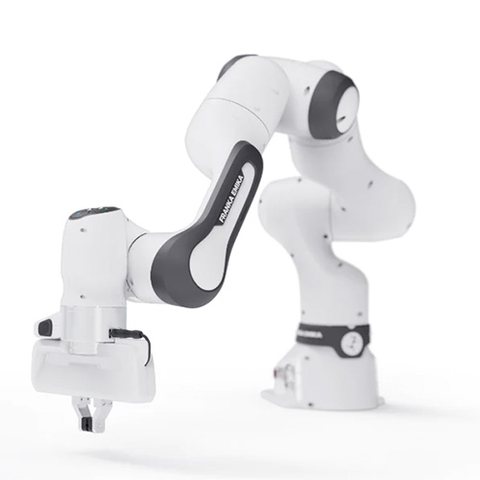
Robots I've worked with
Building a foundation model for social humanoid interaction.
VLA models and RL fine-tuning for precise manipulation and humanoid control, imitation learning for bi-manual assembly, and sound source localization for Samsung Ballie.
IROS 2026 Best Paper Award Finalist10 of 1,585 accepted (top 0.6%) · 4,348 submitted
CVPR 2024 Highlight324 of 2,719 accepted (top 11.9%) · 11,532 submitted
Removing unwanted objects from video with segmentation, inpainting, and animation models. I implemented the VINet-based inpainting stage.
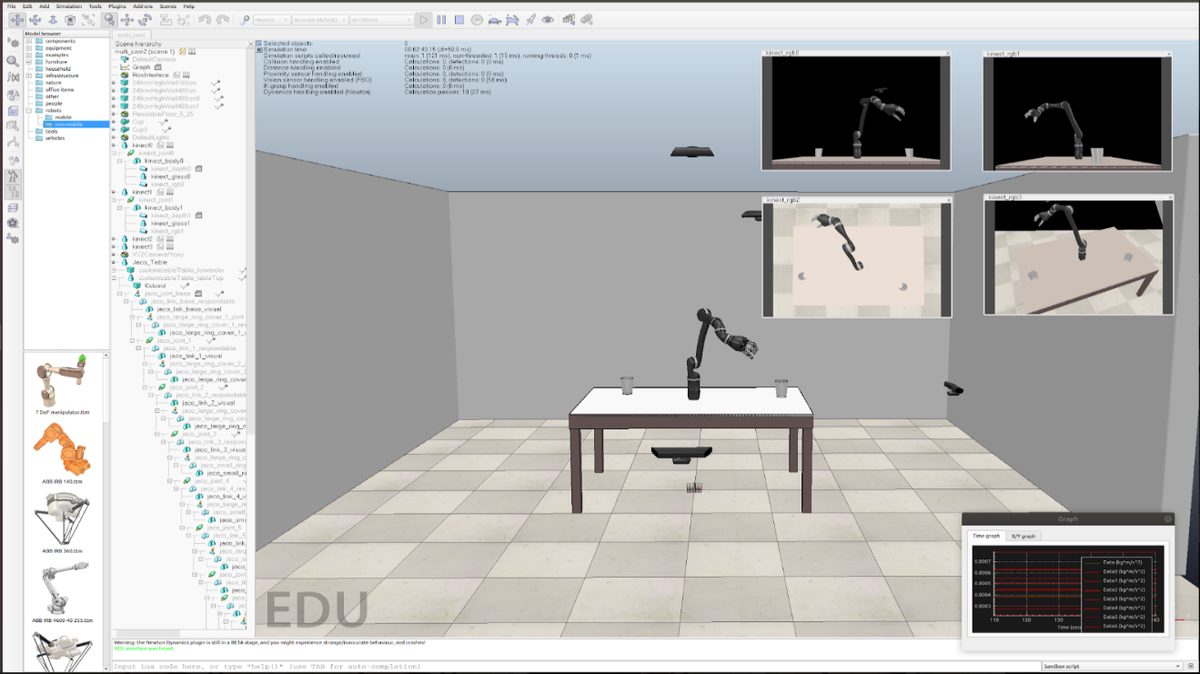
A multi-modal VAE that fuses RGB-D images, joint states, and pressure data for reinforcement learning of a robotic arm (graduation thesis).
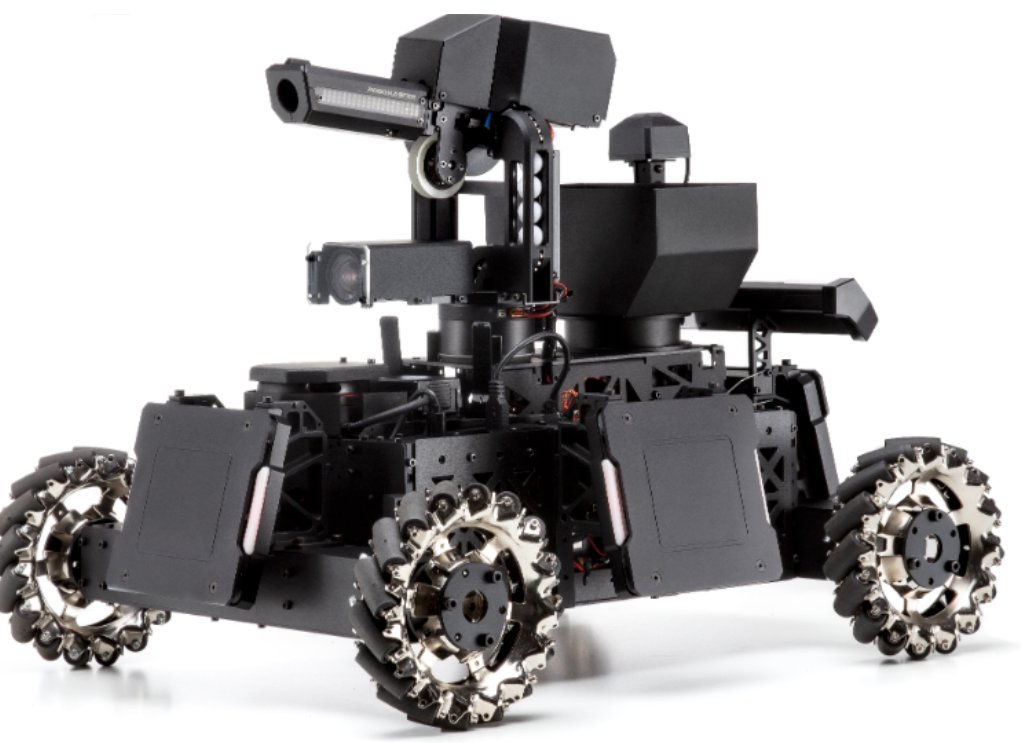
Led Yonsei's team Roboin to 3rd place among 39 teams. Navigation (DWA), YOLOv3 perception, and RL-based behavior policies.